Window cleaning robotics
Cleaning glass within the selected machine’s supported surfaces.
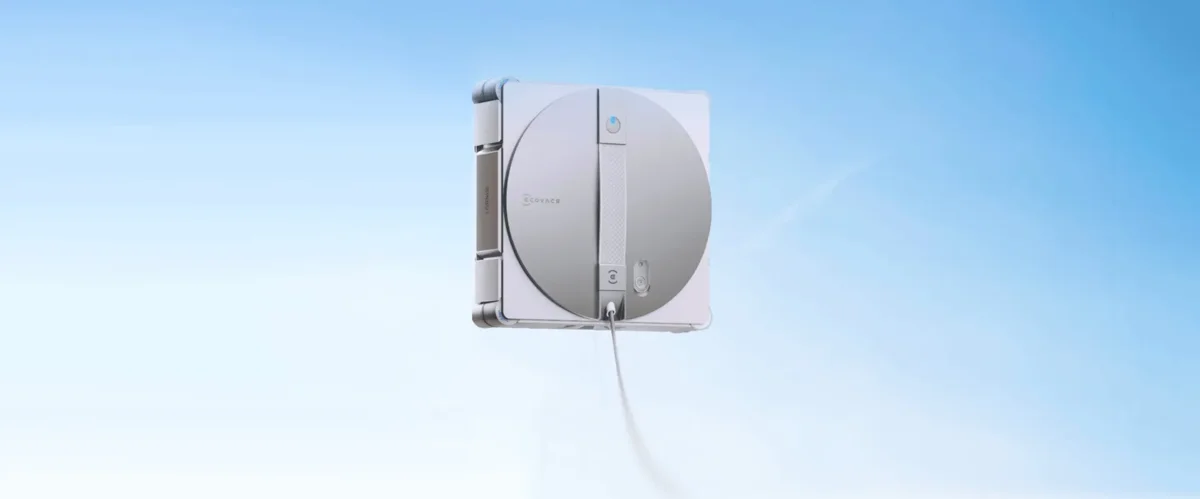
Define the operating envelope.
The objective: cleaning glass within the selected machine’s supported surfaces. Start with one bounded workflow and record how it is completed today. The decision owner is typically among homeowners with accessible compatible glazing. Document where human judgment remains necessary before selecting a machine.
The environment is part of the specification.
Framed versus frameless glass, outdoor access, tether anchor, and power-loss recovery. Build these conditions into the demonstration, including the less convenient parts of a normal operating day. Confirm recovery behavior, maintenance access, and who owns an unresolved exception.
Prove the workflow.
- Edge handling on each pane type
- Safe tether setup
- Cleaning solution and pad replacement
Measure useful output.
Setup time per window
Manual finishing needed
Compare the baseline with pilot results, including human assistance, failed cycles, consumables, and service time.
Continue at the source.
These manufacturer profiles are research starting points. Product fit, configuration, regional availability, and support for your specific task must be confirmed directly.
Your application shortlist.
Save this application in this browser, add private planning notes, and download your shortlist as a JSON file. Nothing is submitted or dispatched.
Open my plannerPlan the full lifecycle.
Keep capability in circulation.
Explore actual renewed inventory at RestoredBots, or request a repair review through SWAT.network. Technician assignment depends on reviewed qualifications, scope, location, customer setup, and availability.
Explore renewed robots ↗Adjacent applications.
Lawn & garden
Maintaining defined lawn areas with robotic mowing.
View application brief ↗residential / Pools & water carePools & water care
Automating compatible pool-floor and wall cleaning.
View application brief ↗residential / Companions & robot petsCompanions & robot pets
Exploring interactive machines and programmed behaviors.
View application brief ↗